
Custom EO/IR Gimbals
Custom EO/IR Gimbals
When an off-the-shelf gimbal does not fit the size, sensor set or interfaces you need, we design a stabilized gimbal for your platform and mission: mechanics, motors and encoders, stabilization control, integration and boresight alignment of day, thermal and laser rangefinder sensors, and prototype testing. Country of origin: Taiwan.
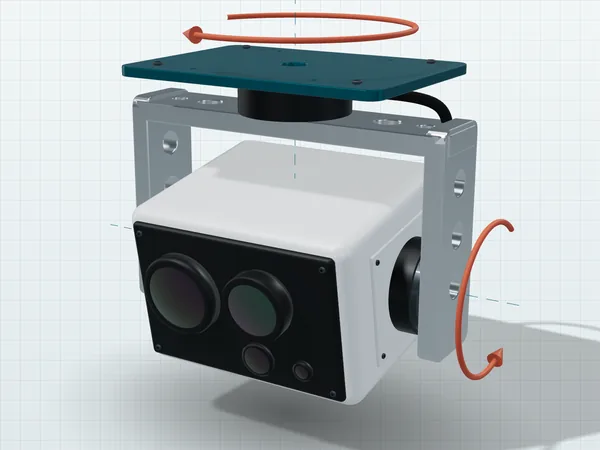
Development scope
| Stage | Content | Deliverable |
|---|---|---|
| Requirements and specification | Platform and mounting interface, sensor set and weight, pointing range and speed, stabilization accuracy, environment, power and communication interfaces | Specification |
| Mechanical design | Number of axes and travel, center of gravity and counterweights, structural stiffness, sealing and heat dissipation | 3D model and drawings |
| Drive and control | Motor, encoder and drive selection; gyro-feedback stabilization; pointing and tracking command interface | Control architecture and tuning parameters |
| Sensor integration | Mounting, boresight alignment and video output for day, thermal and laser rangefinder sensors | Boresight calibration record |
| Prototype and testing | Stabilization accuracy, pointing accuracy and boresight consistency; environmental testing on request | Test report |
You can commission only some of the stages. Environmental tests can be reported through a partner TAF-accredited laboratory, within the scope of its accreditation.
What to include in a quote request
- Platform (UAV, vehicle, vessel or fixed site) and mounting interface
- The sensors to be installed, or the sensor specification you would like us to propose
- Weight, size and power limits
- Pointing range, slew rate and stabilization accuracy requirements
- Environment: temperature, vibration, water and dust protection
- Video output and control interfaces
- Quantity and schedule
The most common design problems are covered in our articles on gimbal stability and why EO/IR dual-sensor payloads fall out of alignment, and payload planning on our UAV EO/IR payload page. For an off-the-shelf gimbal, see EO/IR gimbals; for isolators and adapter plates, see payload mounting parts.
Related products
Original illustration, not a product photo. Actual appearance varies by model.
Want to check feasibility first?
Tell us the platform, sensors and accuracy requirements; we will assess feasibility and schedule before quoting.